VL53L1X Distance Sensor Setup
VL53L1X is an STMicroelectronics I2C ToF (Time-of-Flight) laser rangefinder with a 4-meter effective range. Common applications include precision landing assistance.
Hardware Wiring#
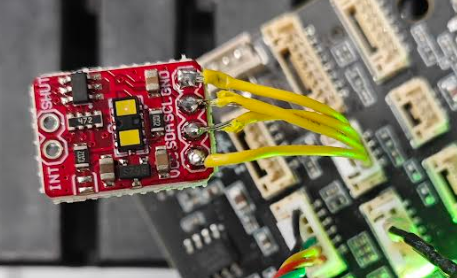
Connect VL53L1 to the I2C external port on SparkNavi Blue:
| Pin | Signal | VL53L1X |
|---|---|---|
| 1 | +5V | VCC |
| 2 | I2C2_SCL | SCL |
| 3 | I2C2_SDA | SDA |
| 4 | GND | GND |
ArduPilot Parameters#
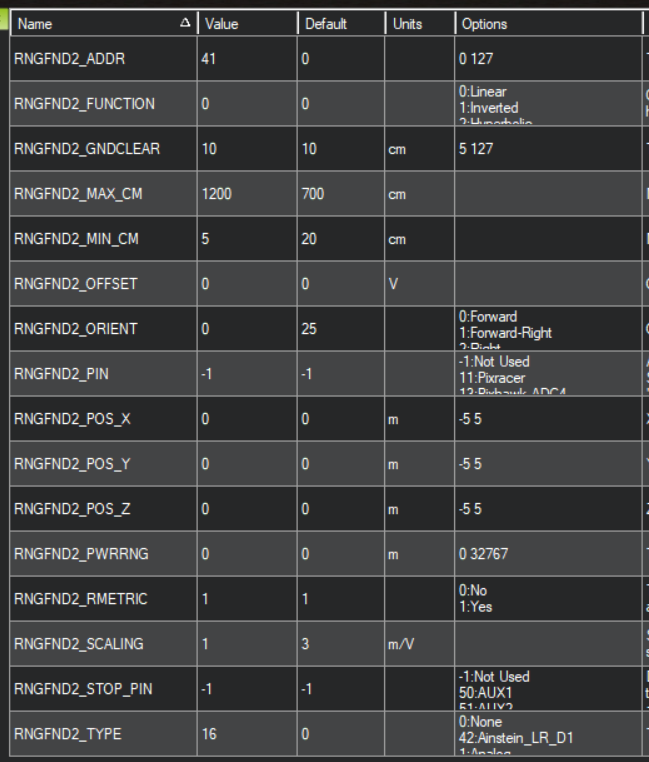
In Mission Planner Config → Full Parameter List:
| Parameter | Value | Description |
|---|---|---|
RNGFND2_TYPE | 16 (VL53L1X) | Rangefinder type |
RNGFND2_ADDR | 41 | I2C address (0x29 = 41, VL53L1X default) |
RNGFND2_MIN_CM | 5 | Minimum range |
RNGFND2_MAX_CM | 1200 | Maximum range |
RNGFND2_ORIENT | 25 (Downward) | Pointing down |
RNGFND2_GNDCLEAR | 10 | Mounting height above ground (cm) |
Why RNGFND2 Instead of RNGFND1#
If you already use the MTF-01 optical flow as the primary rangefinder (RNGFND1), VL53L1X works as a secondary rangefinder (RNGFND2) for precision landing or redundancy.
If using only VL53L1X without optical flow, set RNGFND1_TYPE = 16 instead.
Verification#
After reboot, sonarrange2 (or sonarrange depending on RNGFND number) should appear live in Mission Planner Status.
Move the module from a few centimeters to a meter or more away — the value should respond.